End of arm tooling
End of Arm Tooling Built for Your Robot and Part
Send the part, the robot and the gripper you use, or ask us to choose one. We make the fingers and plates, add the components, assemble and test the tool. Reply within 24 business hours.
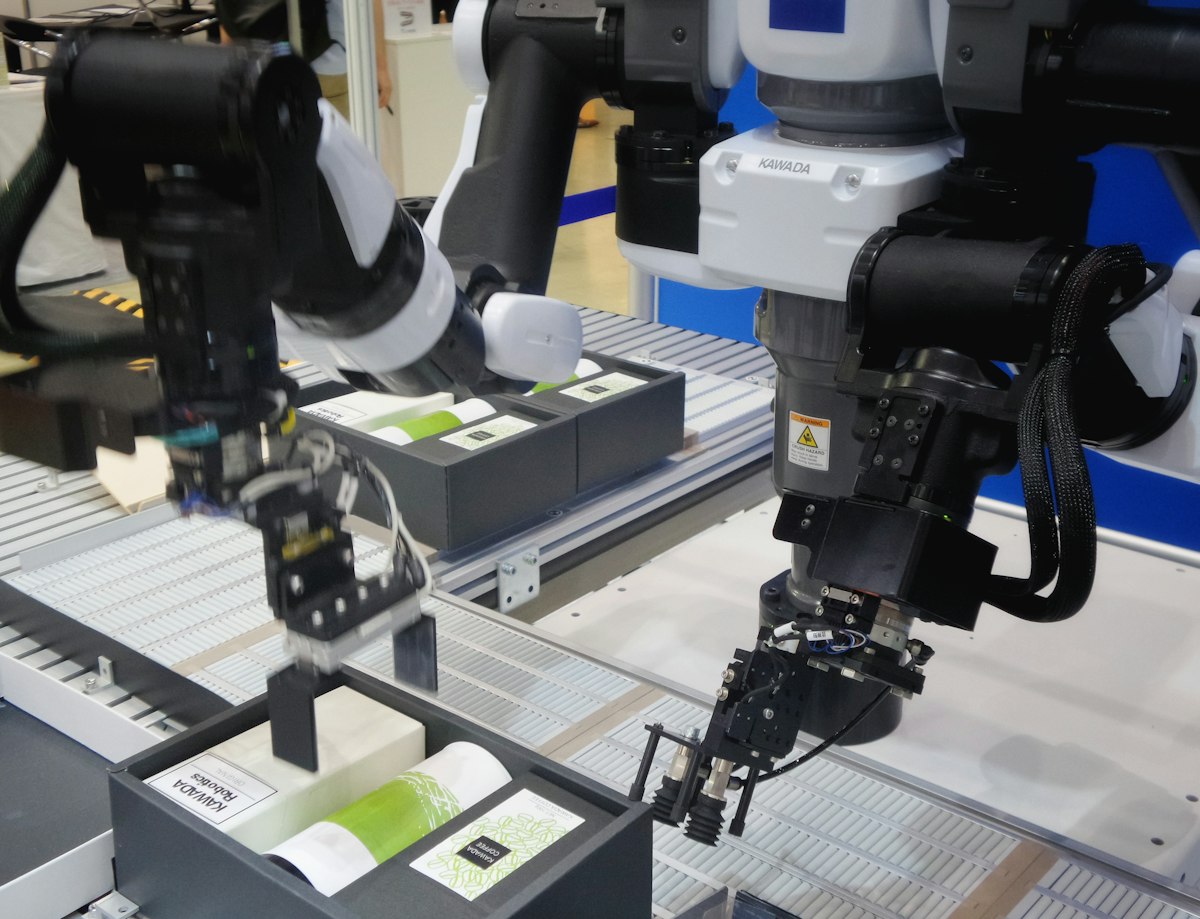
What does your EOAT project need?
Tick what applies. It tells us whether you need parts to drawing or a complete tool.
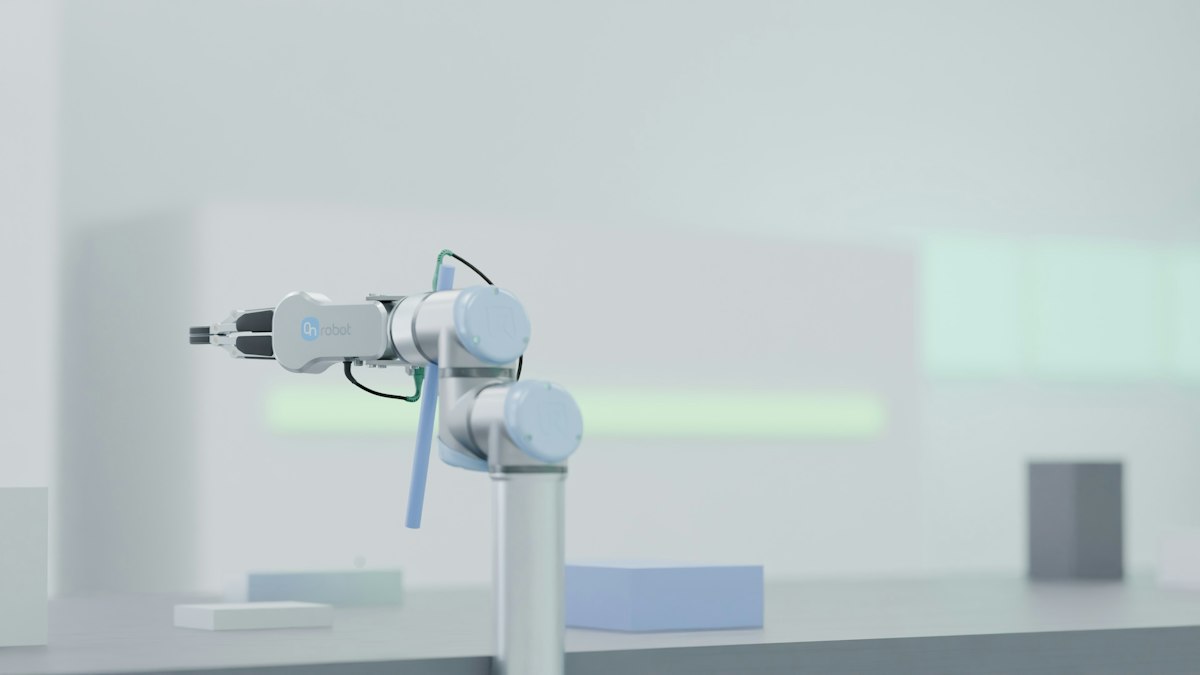
What we make
- Custom gripper fingers
- Adapter and mounting plates
- Vacuum cup arrays
- Pneumatic gripper tools
- Multi-pick tools
- Tool changer plates
- Soft fingers and pads
- Replacement wear parts
Finger material and shape decide grip and part protection. Aluminum, steel, plastics and 3D printed inserts each have a place.
Vacuum or mechanical gripping?
Both pick parts reliably when chosen for the part. The surface, weight and speed decide.
Vacuum
Suction cups or foam pads hold the part by its surface.
- Light, fast and simple
- Flat or smooth parts, boxes, sheets
- Weak on porous or oily surfaces
Mechanical
Pneumatic or electric grippers close fingers around the part.
- Holds heavy or oily parts securely
- Locates the part in the fingers
- Needs fingers made for each part
Typical finger and plate materials
What EOAT parts are usually made from. These are typical choices, not promises. Your quote lists the material for each part.
| Material | Used for | Typical note |
|---|---|---|
| Aluminum 7075 / 6061 | Plates, fingers, frames | Light and stiff, anodized |
| Steel 4140 / tool steel | Fingers under high load or wear | Hardened where it contacts |
| Delrin, nylon | Fingers and pads on finished parts | No marks, low weight |
| Urethane | Soft pads and inserts | Grip on fragile or uneven parts |
| Carbon fiber tube | Long frames for multi-pick tools | Very light, low inertia |
Where our tools run
Tell us the robot, payload and cycle time. The tool is built around them.
Machine tending
Fingers for raw and finished parts in one tool.
Packaging and palletizing
Vacuum and fork tools for boxes and bags.
Plastics molding
Sprue pickers and part removal tools.
Automotive
Grippers for stampings, castings and assemblies.
Electronics
Small fingers and vacuum tools for boards and housings.
Food and pharma
Stainless and food safe materials.
How it works
You send the problem. We take it from drawing to delivery and keep you informed at each step.
Send your files
Part drawings, robot model, gripper or vacuum components you use and the cycle.
We review and quote
We check payload, grip and clearance, then propose the tool or quote your drawings.
We produce and inspect
Fingers and plates machined, components fitted, the tool assembled and function tested.
We deliver
Tool ready to mount, with drawings, component list and spare wear parts on request.
What drives the price of end of arm tooling
Five things decide most EOAT quotes.
- Design workDrawings you supply cost nothing extra. Designing from the part does.
- ComponentsGrippers, vacuum generators and sensors are often half of the price.
- Number of picksMulti-pick tools multiply fingers, cups and valves.
- Weight targetsPocketing and lightweight materials add machine time.
- TestingFunction and grip tests with real parts take time and parts.
Have a part to pick?
Send the short version now. We will ask for anything missing. Prefer to give full details up front? Use the full quote form.
Your files are seen only by our team and the partners working on your project. Ask for an NDA and we sign it first.
Build robot tooling or supply gripper parts?
We work with production shops, component suppliers and engineers in this field. Register once and we send you project scopes that fit what you do. We handle the customer side.
Questions customers ask
Something else? Email .
Can you design the tool from my part?
Yes. Send the part model, the robot model, the pick and place positions and the cycle. We propose the gripping method and the tool in 3D for approval.
Which gripper brands do you use?
The ones your plant uses, so spares stay simple. Tell us the brand and series. If you have no preference, we propose standard components that are easy to buy.
Do you test the tool?
Yes. Every complete tool is assembled and function tested before shipping, with your parts when you send samples.
Can you make replacement fingers?
Yes. Send a drawing or the worn finger. Spare sets are the most common repeat order.
Do you make the tools yourselves?
Production runs at partner shops we have audited for this kind of work. We stay responsible for the order: we review the drawing, pick the shop, follow production, inspect before shipping and deliver to you. You deal with one contact and one purchase order.
Can you sign an NDA first?
Yes. Tick the NDA box on the quote form and we sign one with you before anyone outside our team opens your files. Every partner on the project works under the same terms.